SPIKE Lab
Sensor · Perception · Inference · Knowledge for Embodiment
Pioneering neuromorphic vision and computer vision for intelligent embodied systems.
Principal Investigator
Meet the team →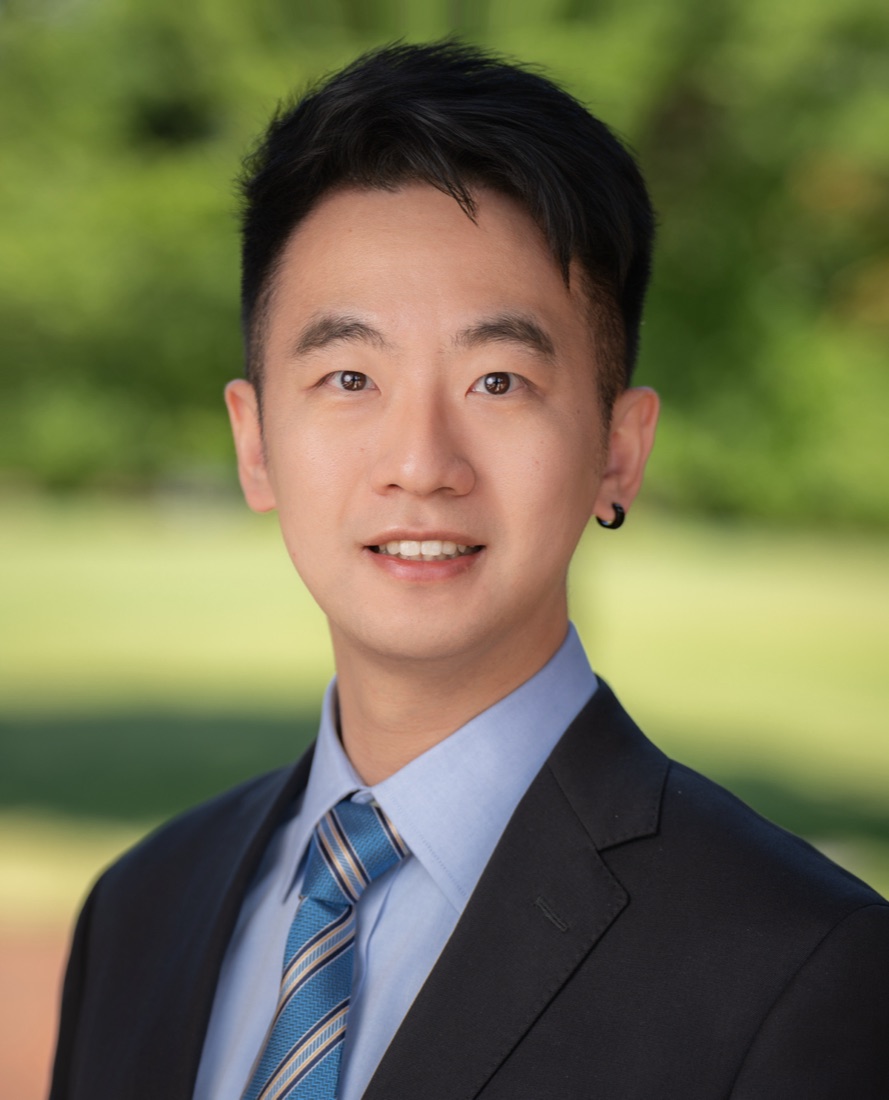
Ziyun (Claude) Wang
Assistant Professor, Electrical and Computer Engineering
Dr. Wang is an Assistant Professor in the Department of Electrical and Computer Engineering at Johns Hopkins University, where he leads the SPIKE Lab. His research sits at the intersection of computer vision, robotics, and neuromorphic computing, with a focus on event-based, continuous-time perception — building systems that see and act at the speed of the physical world. He received his Ph.D. from the GRASP Laboratory at the University of Pennsylvania, advised by Prof. Kostas Daniilidis. Before joining Hopkins, he interned with the Vision Product Group at Apple and was a research intern at the Samsung AI Center in New York, collaborating with Professors Sebastian Seung, Daniel Lee, and Volkan Isler.
- [email protected]
- Office
- Barton Hall 231
News
-
SPIKE Lab is co-hosting the IROS 2026 workshop “Perception and Decision Making for Athletic Humanoid Robotics” on September 26. See the program for talks and live demos!
-
SPIKE Lab released TRACE, the first trajectory-level ergodic formulation for active Gaussian scene reconstruction, deployed on real robots. Code is available!
-
SPIKE Lab released Isaac Sim Event Simulator v1.0, a physics-grounded, high-rate event camera plugin for NVIDIA Isaac Sim.
-
SPIKE Lab's paper “Match-Any-Events” has been accepted to ECCV 2026 — the first generalizable matching model with events.
-
SPIKE Lab's ICRA 2026 workshop, “Challenges and Opportunities of Neuromorphic Field Robotics and Automation,” has been accepted and will take place on June 5 in Vienna.
-
“Continuous-Time Human Motion Field from Event Cameras” has been accepted at ICCV 2025. See you in Hawaii!
-
“Event-based Continuous Color Video Decompression” will appear in the CVPR 2025 Workshop on Event-based Vision.
Show earlier newsHide earlier news
-
“EqNIO: Subequivariant Neural Inertial Odometry” has been accepted at ICLR 2025.
-
Four papers accepted to ECCV 2024. See you in Milan!
-
The M3ED dataset (Multi-Robot, Multi-Sensor, Multi-Environment Event Dataset) is presented at the CVPR event vision workshop.
-
“EV-Catcher: High-Speed Object Catching Using Low-Latency Event-Based Neural Networks” is accepted at RA-L.
-
“EvAC3D: From Event-Based Apparent Contours to 3D Models via Continuous Visual Hulls” was selected as an oral presentation at ECCV 2022. See you in Tel Aviv!
Research Areas
Explore our research →Sensors
Developing advanced neuromorphic vision sensors and bio-inspired sensing systems for efficient visual processing.
Perception
Creating robust perception algorithms that can process and understand complex visual information in real time.
Inference
Building intelligent systems that can make real-time decisions and inferences from visual and sensory data.
Knowledge
Developing frameworks for embodied AI systems to learn and accumulate knowledge from their interactions.
Embodiment
Bringing perception and learning onto real robots, from high-speed catching to active scene reconstruction, closing the loop between sensing and acting.
Join Our Lab
We are recruiting Ph.D. students for the Fall 2027 application cycle. If you're interested in real-time perception, learning for robotics, or neuromorphic computing, we'd love to hear from you!
Ph.D. Positions
Funded positions for Fall 2027, for students interested in:
- Real-time perception
- Learning for robotics
- Neuromorphic computing
- Event-based vision
Research Assistants
Opportunities for JHU students to gain hands-on research experience in:
- Computer vision
- Robotics projects
- Deep learning
- Hardware development
How to Apply
Email [email protected] with the subject line [PhD Application 2027] Your Name, and include:
- Your CV
- Transcript (unofficial is fine)
- A short statement of interest or description of your research background